Collaborative-robot control software
We developed software that runs on the controller of an industrial collaborative robot built to work beside people. Robots like this go into processes such as welding, assembly, and logistics where people work alongside them. Unlike an app that draws screens, this code turns into the movement of a real machine, so a mishandled state or a data error becomes a motion error. Handling inputs, state changes, and exceptions conservatively was the rule. The work covers the module structure of the control functions and the data handling that stores and reads settings and control state.
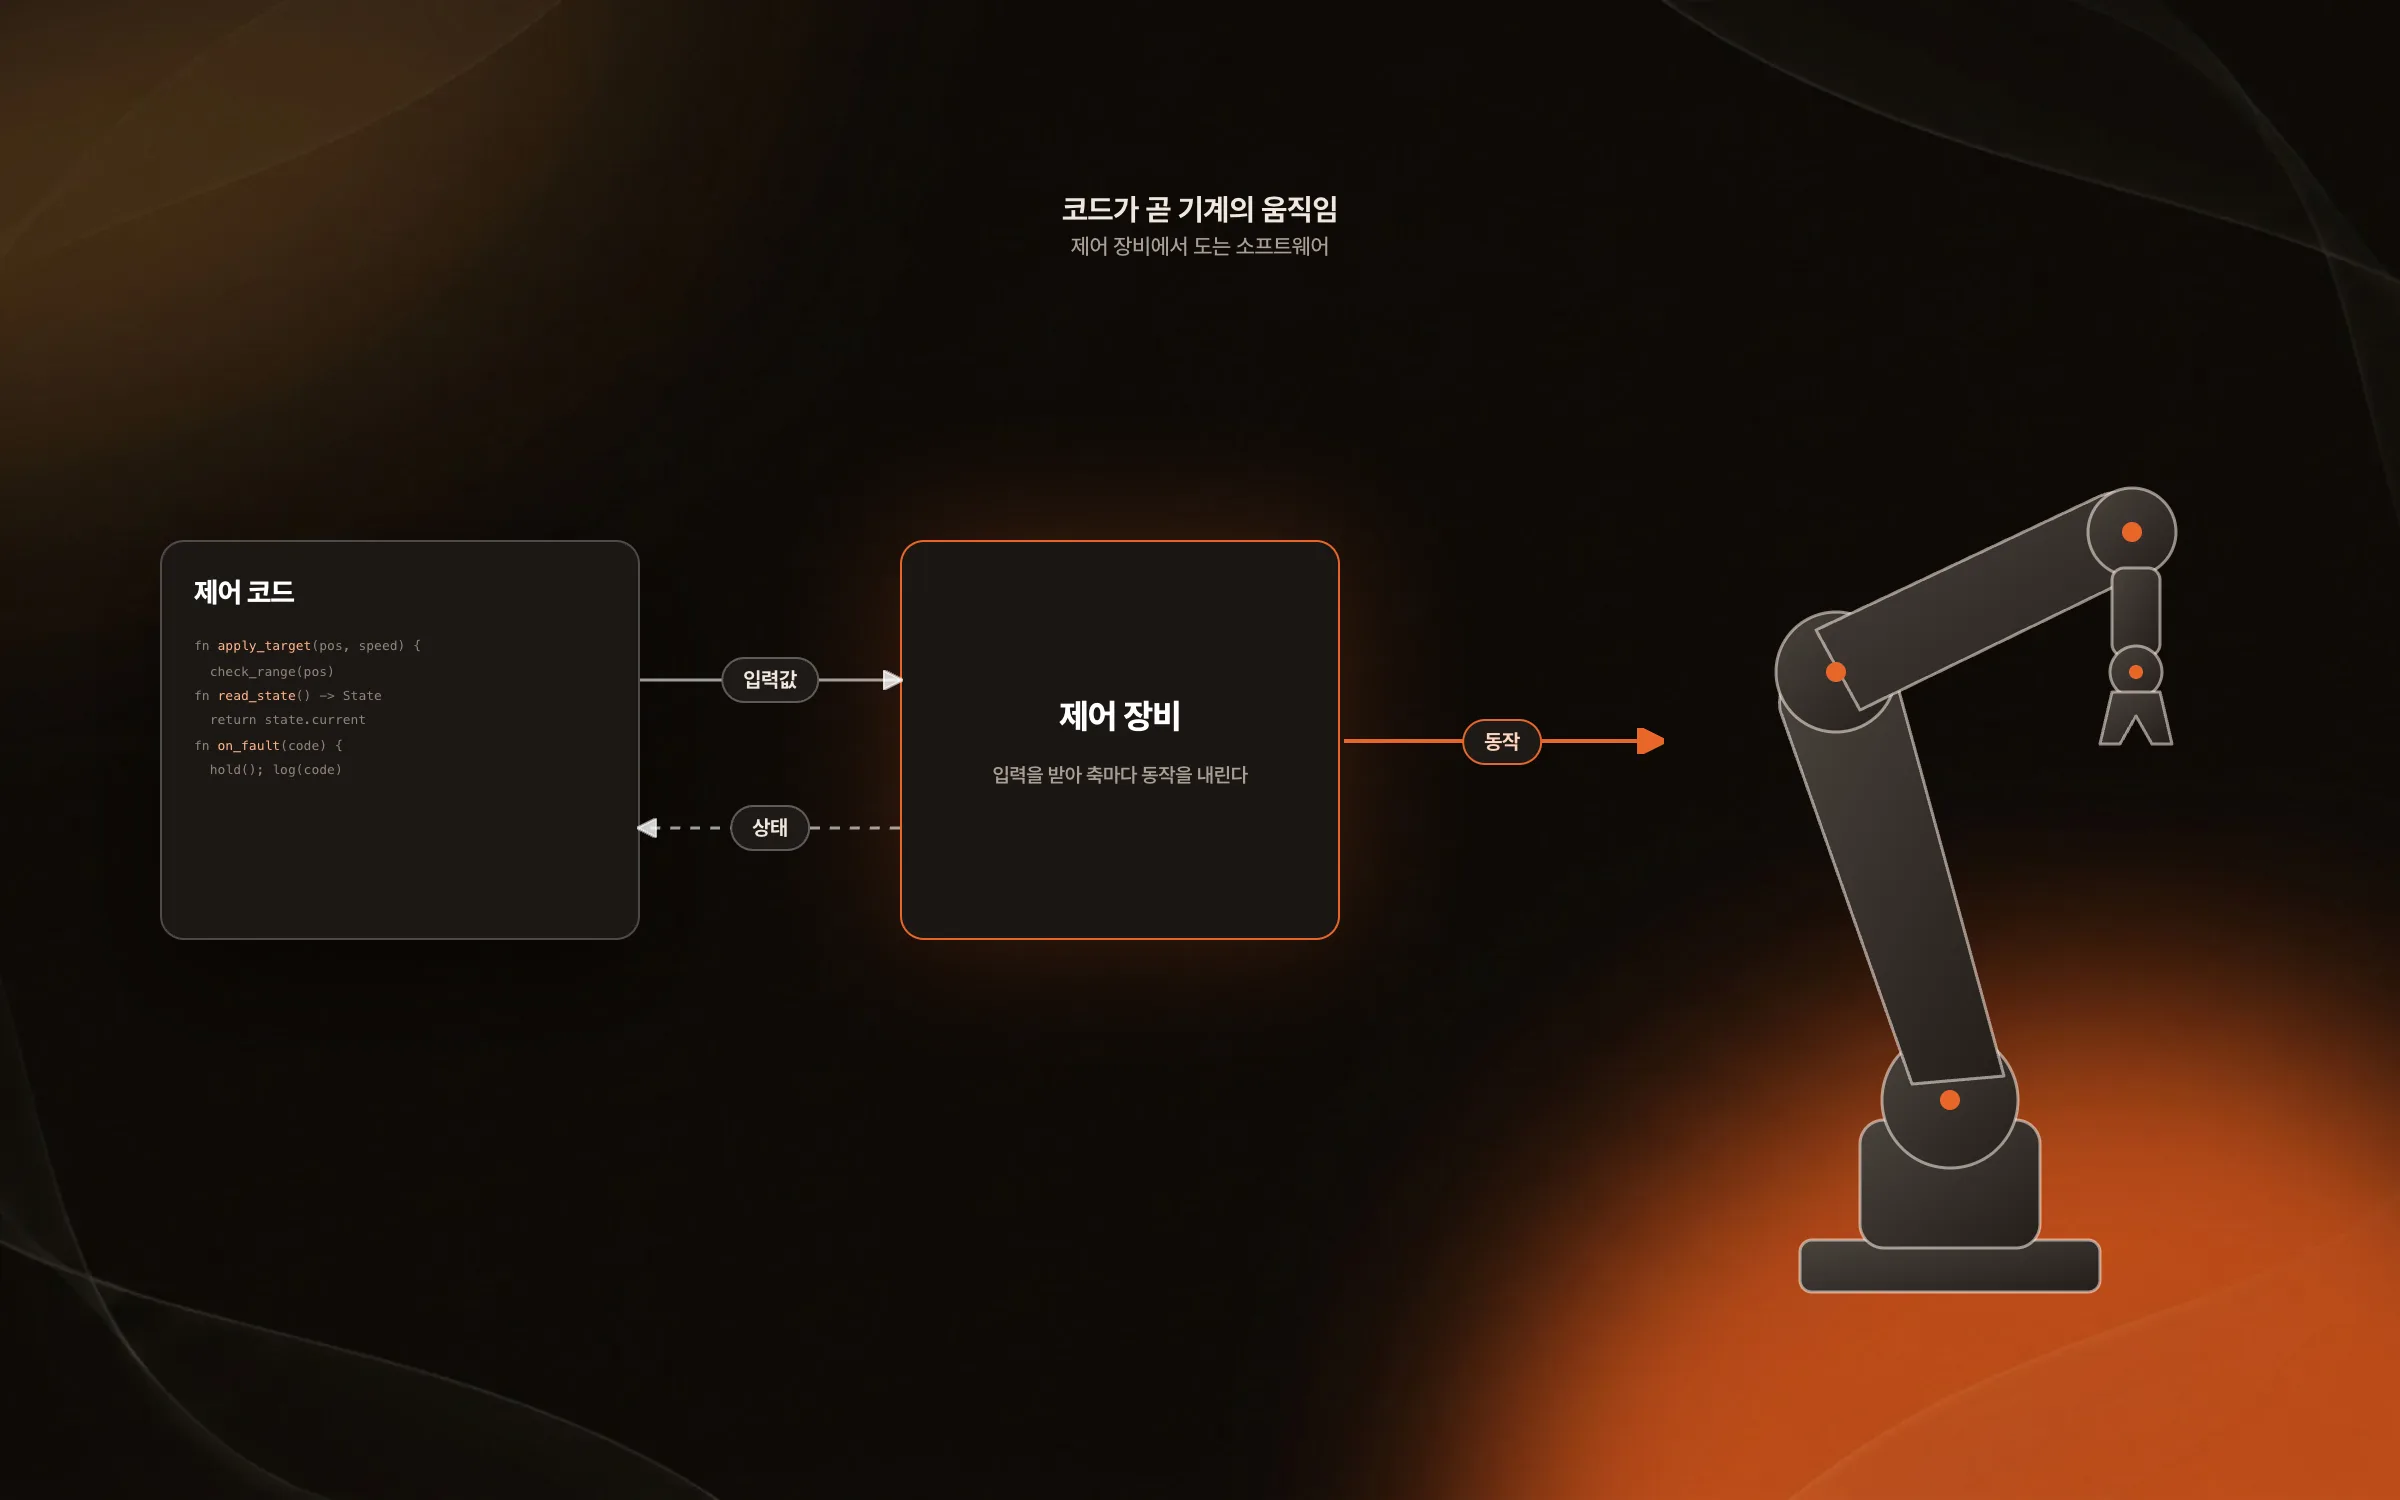
Control software where code becomes the machine's movement
A collaborative robot is an industrial robot built to work side by side with people on the factory floor, and we developed software that runs on its controller. A collaborative robot carries force sensors in its joints and is built to stop when it senses even a small force, such as contact with a person. Unlike an app that draws a user interface, this code connects directly to the equipment's actual motion. Inputs, state changes, and exception handling were treated more conservatively than in app work.

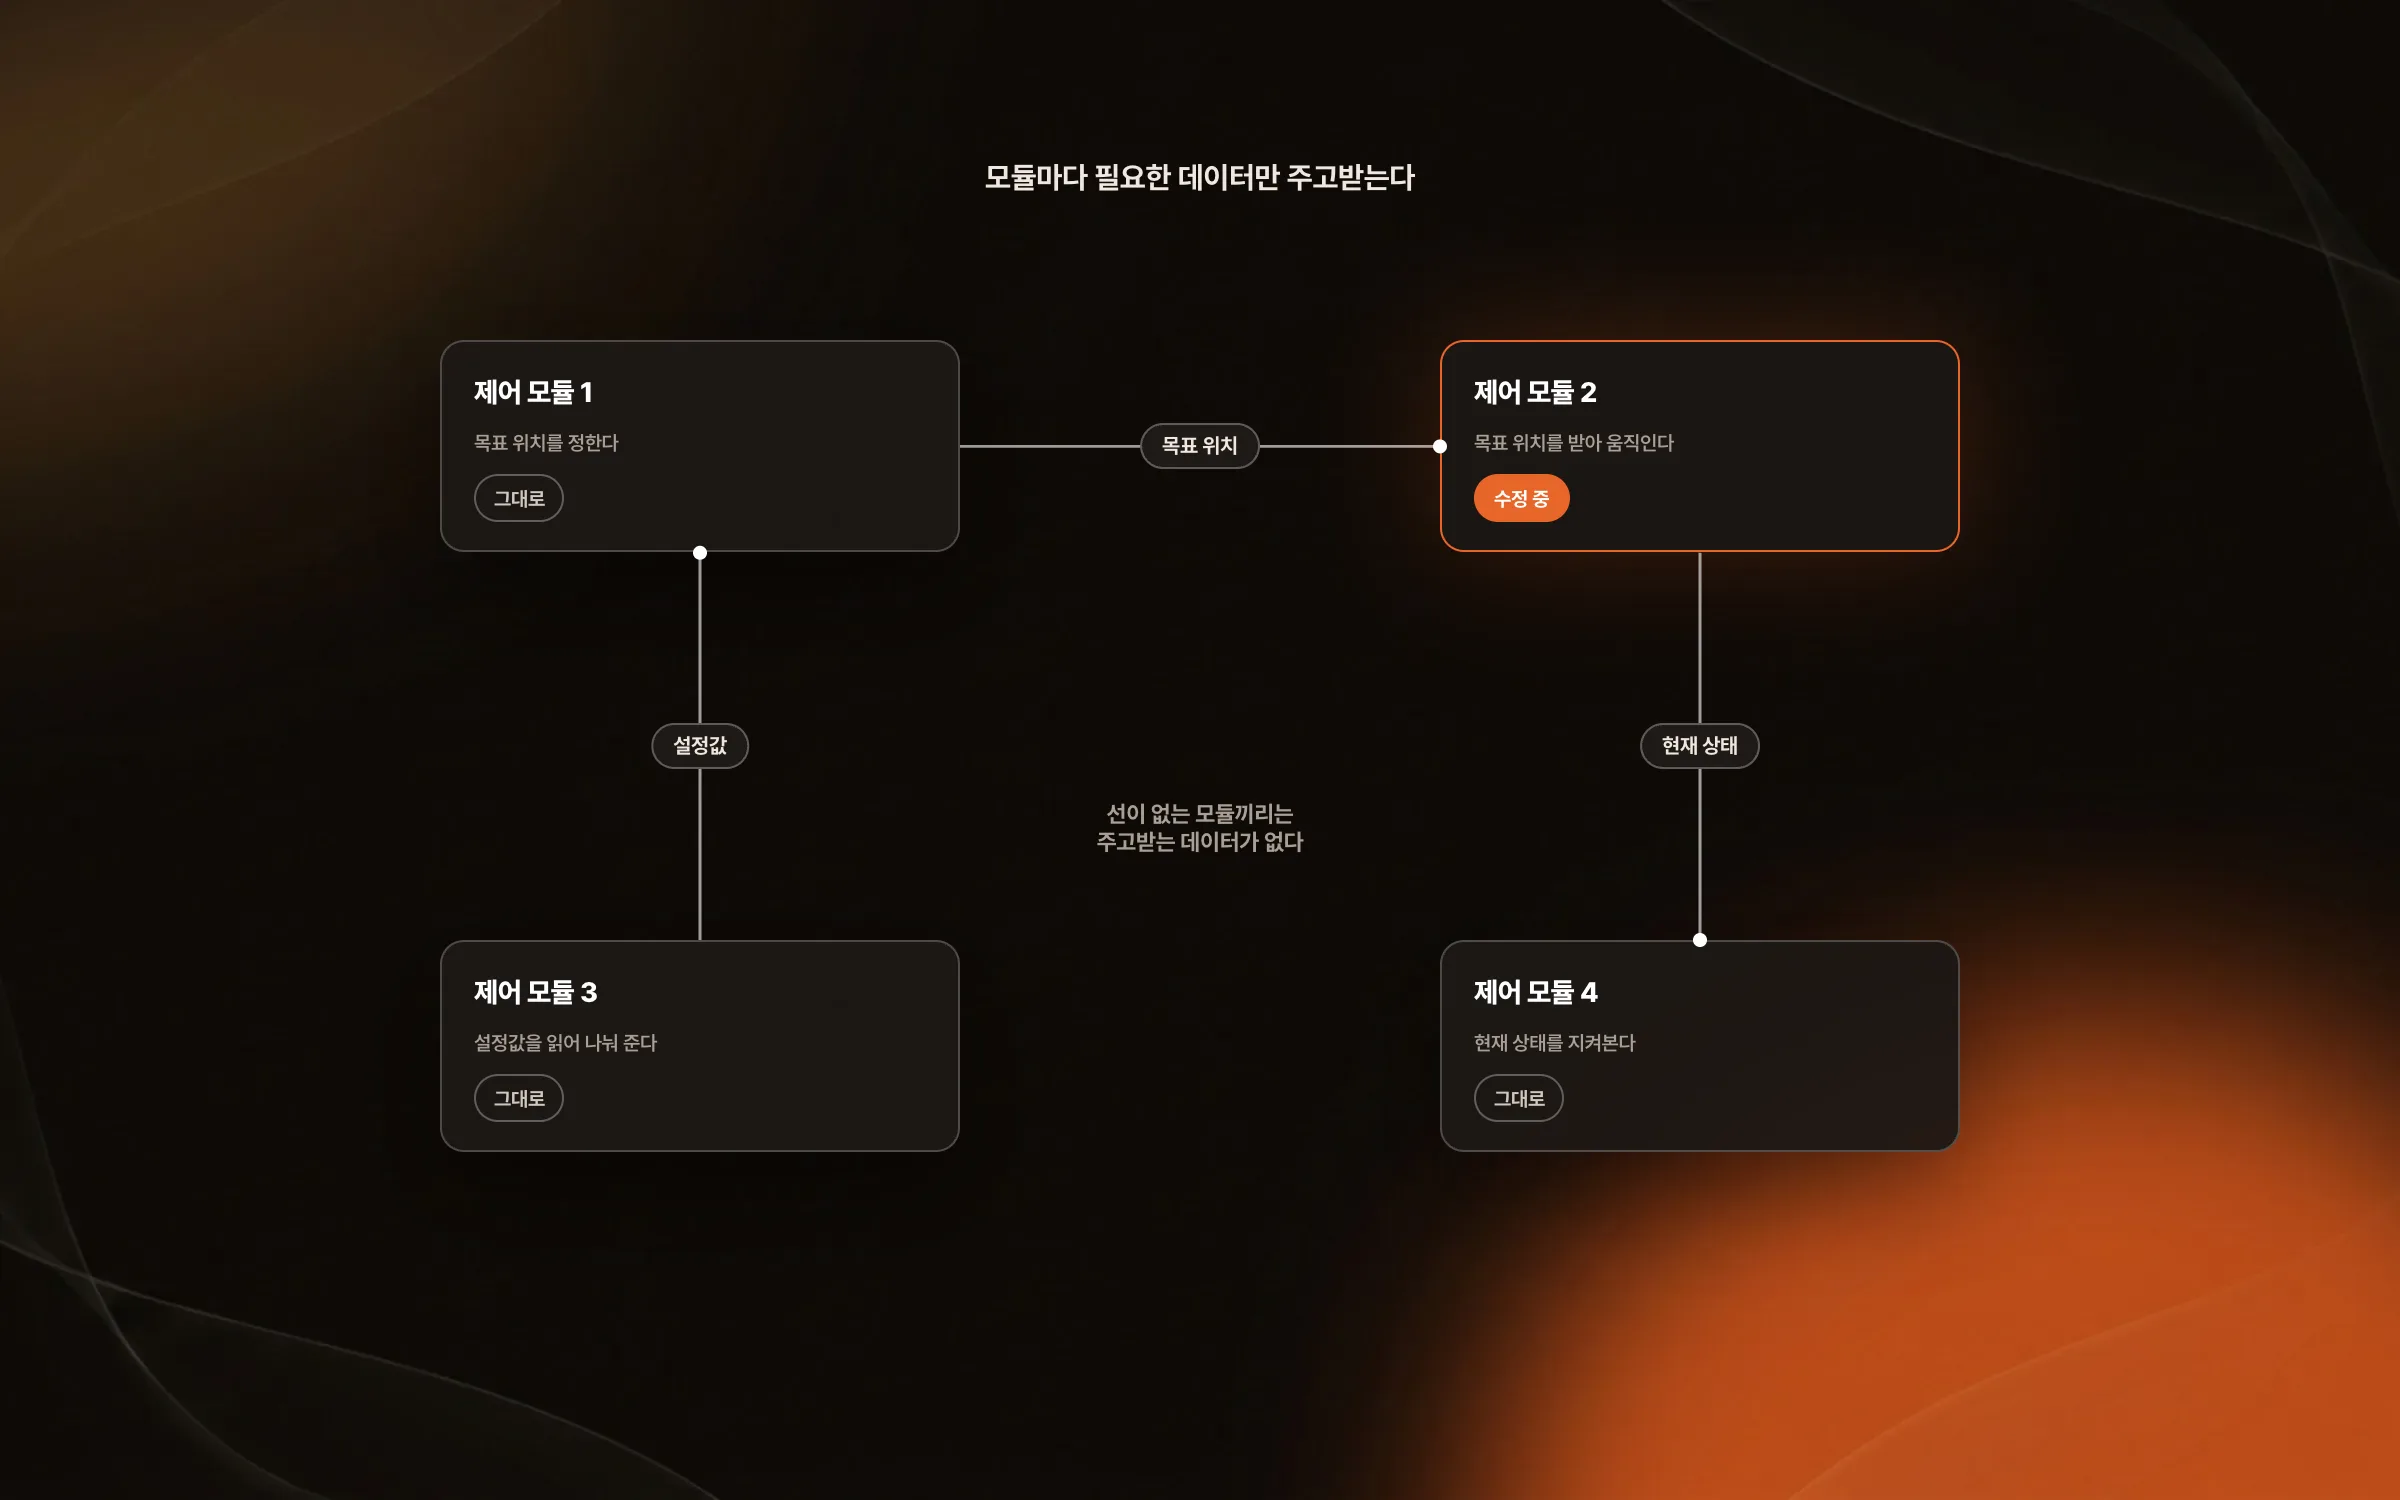
Modules split by control unit, passing only the data they need
In the collaborative robot's control software, the robot control functions were split into modules by control unit. Each module runs independently and exchanges only the data it needs, so the complexity of the control logic does not pile up in one place. Changing one module does not mean reworking the other control functions along with it.

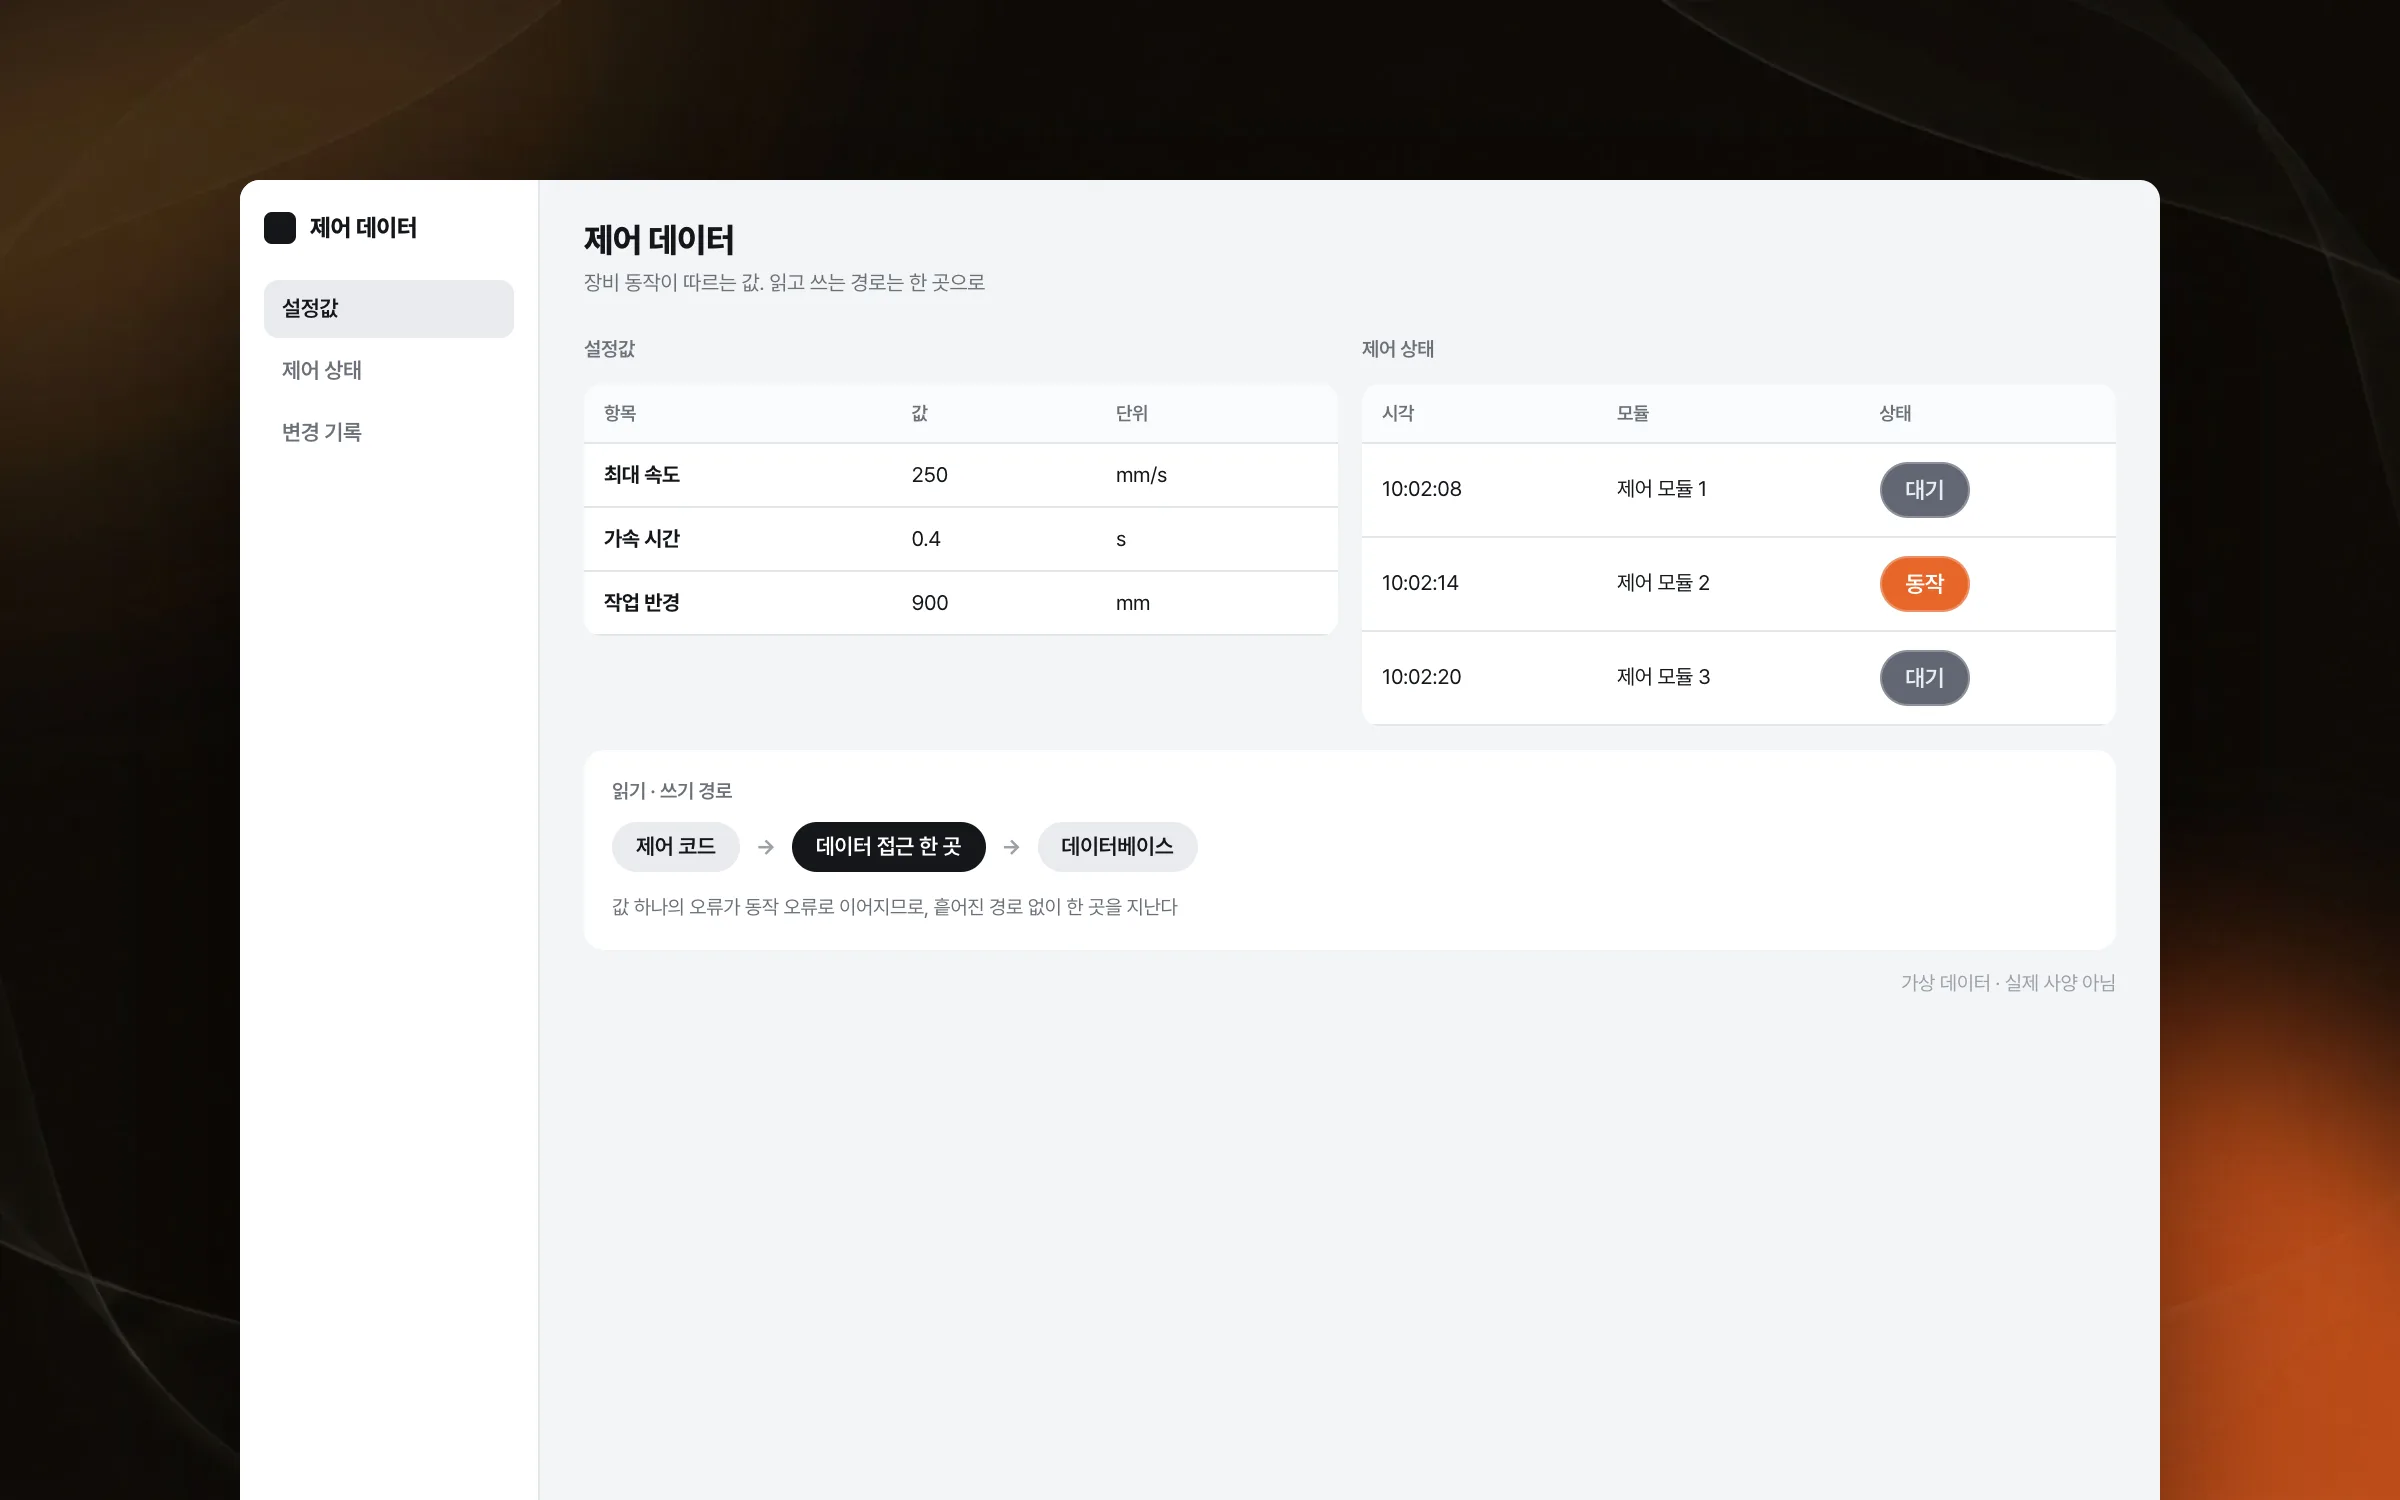
Keeping settings and control state in a database
We implemented the structure that stores and reads the settings, control state, and other data the collaborative robot needs to operate in a database. The paths by which the control code reads and writes data were tidied so access to data does not scatter in many directions. Because the equipment's motion follows this data, a single wrong value could lead to a motion error.

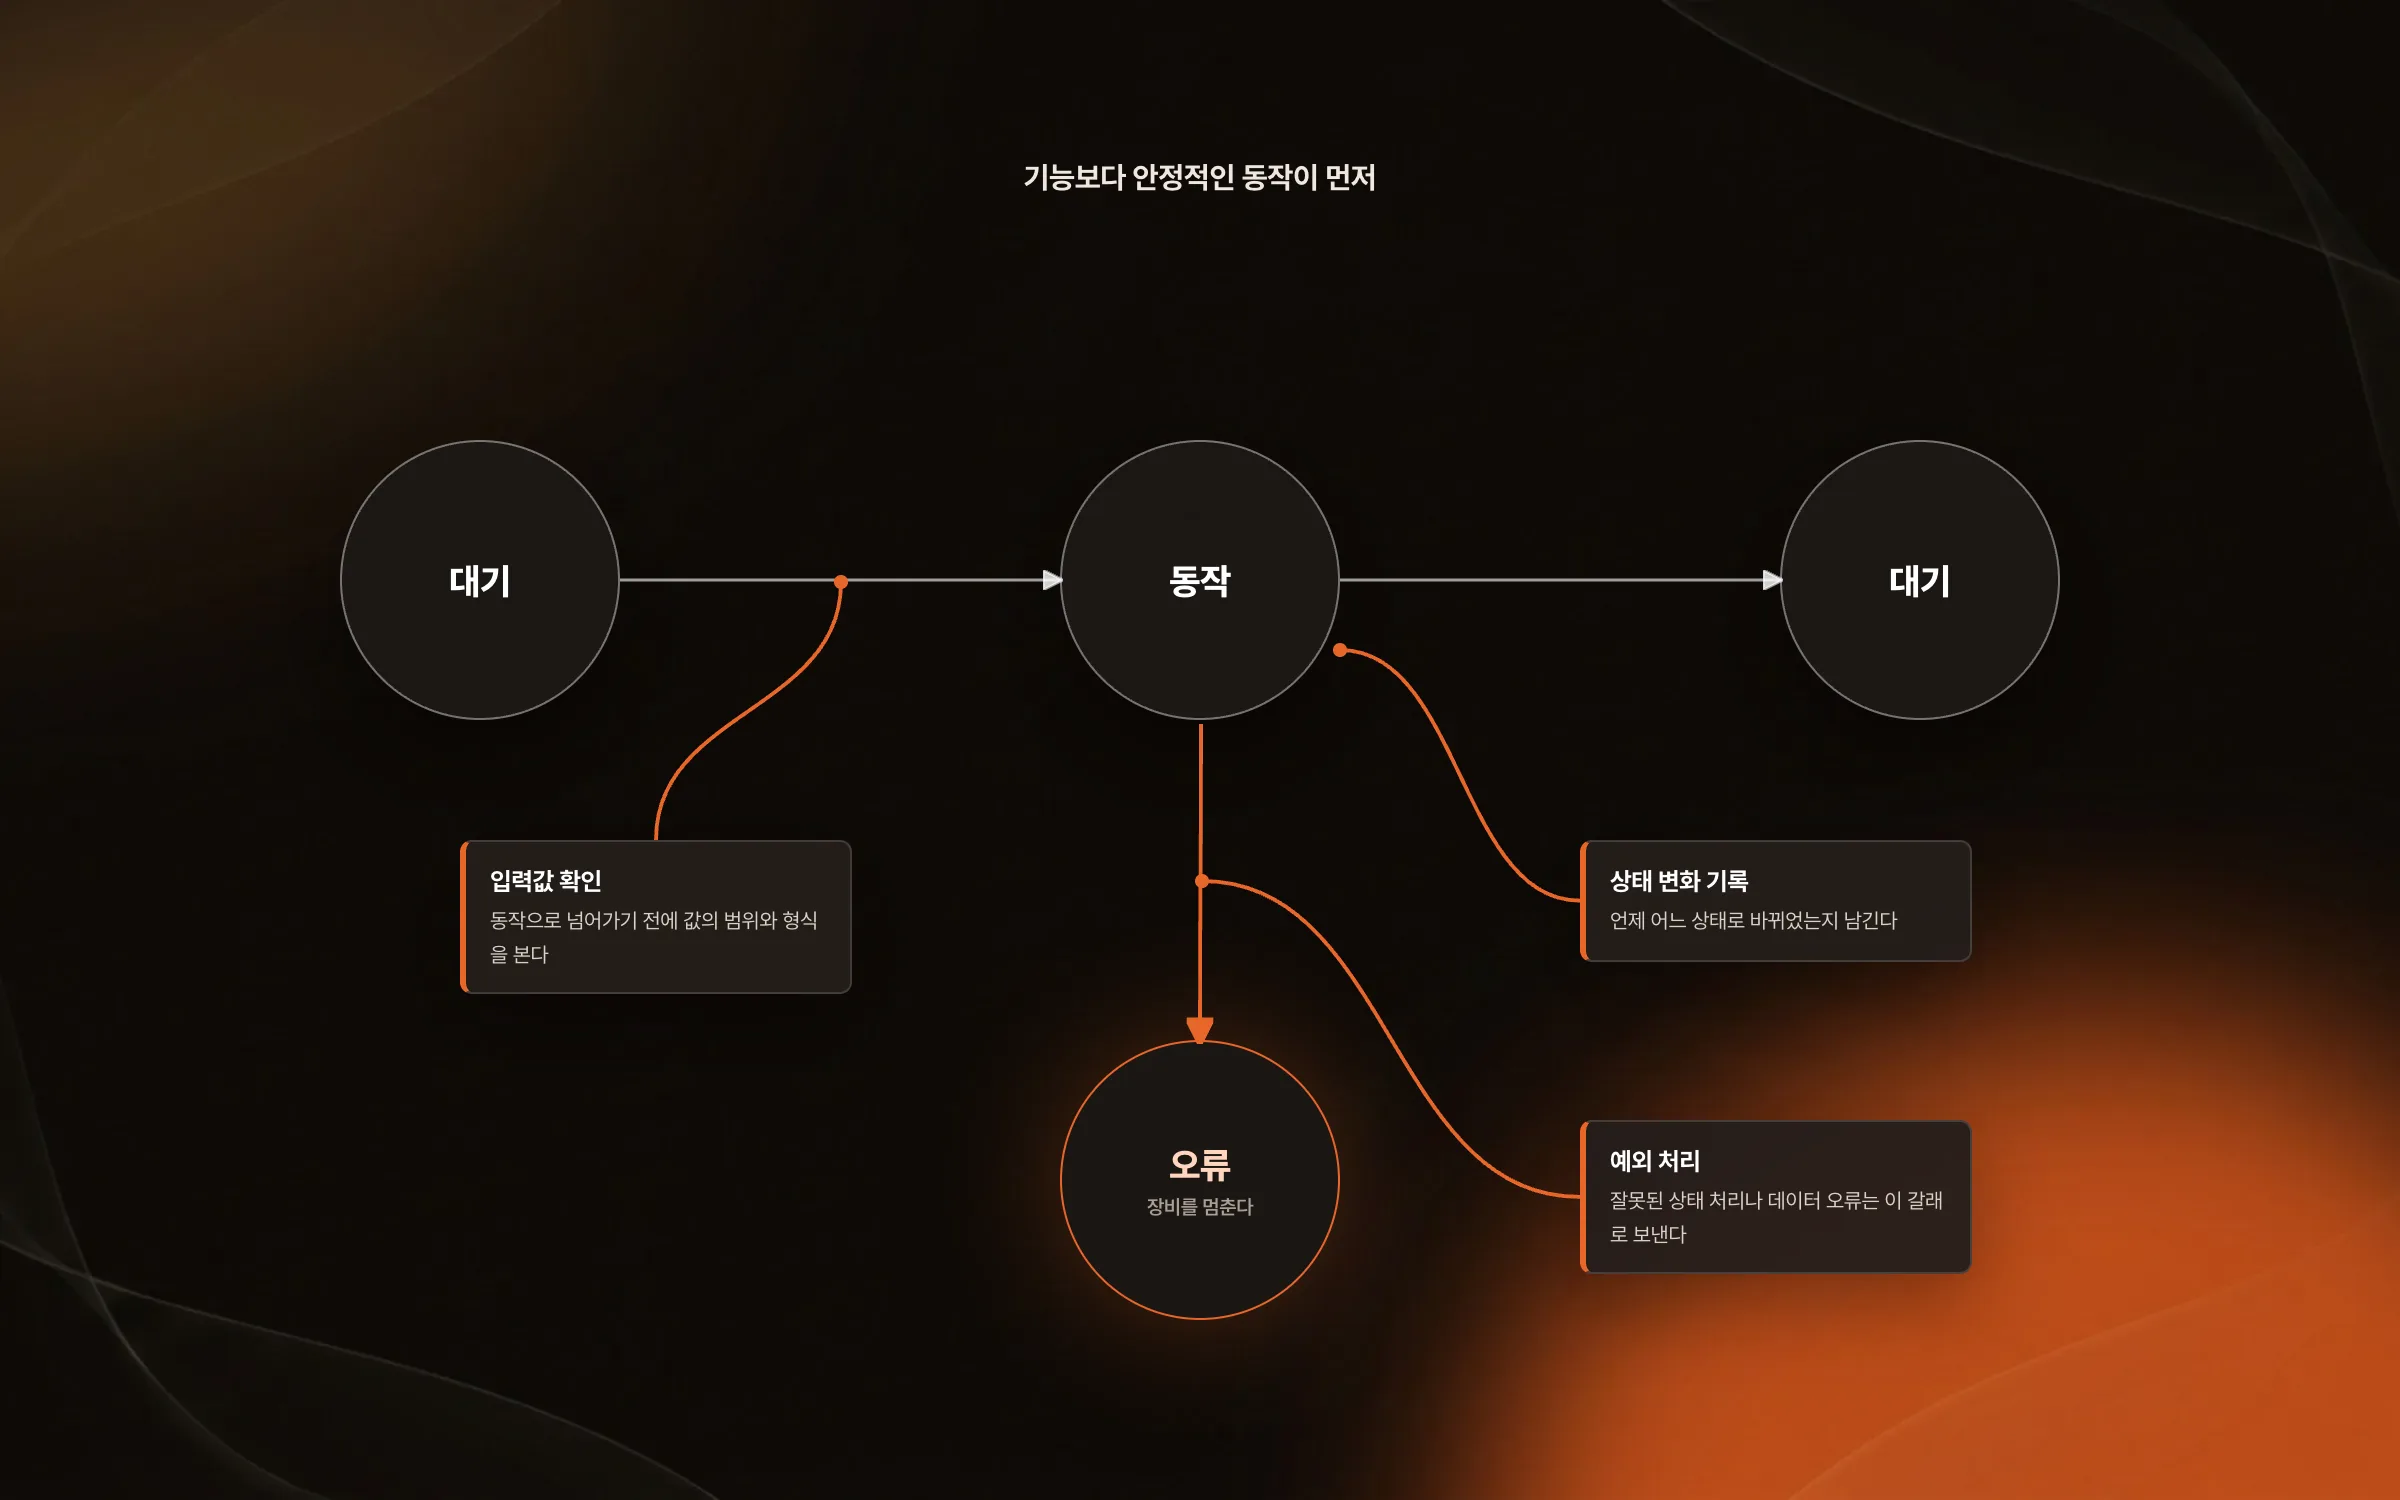
A control flow that puts stable motion ahead of features
A collaborative robot is connected to real physical equipment, so a mishandled state or a data error becomes a motion error. We handled control data and code flow carefully and put stable operation ahead of adding features. Unlike screen-centred app development, in this field the stability of the equipment's motion and the reliability of the control logic decide the outcome.

Highlights
A module structure split by control unit, passing only the data each needs
Control-data handling that stores and reads settings and control state in a database
An equipment control flow that treats inputs, state changes, and exceptions conservatively
Insights
GA4 client_storage: 'none'은 정말 쿠키를 막을까?
두 달 전 이 블로그에 「GA4 쿠키 없이 쓰기」라는 글을 썼습니다. clientstorage: 'none' 으로 쿠키 저장을 끄고, 자체 분석이 쓰던 익명 ID 를 clientid 로 넘기면 쿠키 0개로 GA4 를 쓸 수 있다는 내…
GA4 Measurement Protocol: gtag.js 없이 서버에서 이벤트 보내기
랜딩 페이지의 전송량을 파일 단위로 쪼개 보다가, 가장 큰 파일이 우리 코드가 아니라는 것을 알았습니다. Google Analytics 의 gtag.js 였고, 방문 한 번에 176KB 를 받고 있었습니다. 페이지 전체가 1,094K…
중소 제조업 AI 도입 순서: DX를 먼저 끝내야 할까?
공장을 가진 중소·중견 제조기업 16만여 곳 가운데 스마트공장을 도입한 곳은 19.5%입니다. 회사가 작을수록 이 비율은 더 떨어집니다. 중소벤처기업부가 2025년 4월에 낸 제1차 스마트제조혁신 실태조사 결과입니다. 그림: 기업 규…
Next.js loading.tsx와 404: 버튼이 화면보다 먼저 살아나게 하기
관리 화면 왼쪽 위에 사이드바를 접고 펴는 ☰ 버튼이 있습니다. 폭 하나 바꾸는 버튼인데, 대시보드에서 누르면 2초 넘게 아무 반응이 없었습니다. 레이아웃만 바꾸는 일이 왜 이렇게 오래 걸리는지부터 들여다봤습니다. Next.js 16…